Quasi-sphere
In mathematics and theoretical physics, a quasi-sphere is a generalization of the hypersphere and the hyperplane to the context of a pseudo-Euclidean space. It may be described as the set of points for which the quadratic form for the space applied to the displacement vector from a centre point is a constant value, with the inclusion of hyperplanes as a limiting case.
Notation and terminology
This article uses the following notation and terminology:
- A pseudo-Euclidean vector space, denoted Rs,t, is a real vector space with a nondegenerate quadratic form with signature (s, t). The quadratic form is permitted to be definite (where s = 0 or t = 0), making this a generalization of a Euclidean vector space.[lower-alpha 1]
- A pseudo-Euclidean space, denoted Es,t, is a real affine space in which displacement vectors are the elements of the space Rs,t. It is distinguished from the vector space.
- The quadratic form Q acting on a vector x ∈ Rs,t is denoted Q(x).
- The symmetric bilinear form B acting on two vectors x, y ∈ Rs,t is denoted B(x, y) or x ⋅ y. This is associated with the quadratic form Q.[lower-alpha 2]
- Two vectors x, y ∈ Rs,t are orthogonal if x ⋅ y = 0.
- A normal vector at a point of a quasi-sphere is a nonzero vector that is orthogonal to each vector in the tangent space at that point.
Definition
A quasi-sphere is a submanifold of a pseudo-Euclidean space Es,t consisting of the points u for which the displacement vector x = u − o from a reference point o satisfies the equation
- ax ⋅ x + b ⋅ x + c = 0,
where a, c ∈ R and b, x ∈ Rs,t.[1][lower-alpha 3]
Since a = 0 in permitted, this definition includes hyperplanes; it is thus a generalization of generalized circles and their analogues in any number of dimensions. This inclusion provides a more regular structure under conformal transformations than if they are omitted.
This definition has been generalized to affine spaces over complex numbers and quaternions by replacing the quadratic form with a Hermitian form.[2]
Geometric characterizations
Centre and radius squared
The centre of a quasi-sphere is a point that is equidistant from every point of the quasi-sphere – i.e., the quadratic form applied to the displacement vector (or radius vector) from the centre to a point of the quasi-sphere yields a constant, called the radius squared, or equivalently, the point at which the pencil of lines normal to the tangent hyperplanes meet. If the quasi-sphere is a hyperplane, the centre is the point at infinity defined by this pencil.
When a ≠ 0, the displacement vector p of the centre from the reference point and the radius squared r2 may be found as follows. We put Q(x − p) = r2, and comparing to the equation above used to define a quasi-sphere, we get

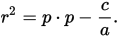
The case of a = 0 may be interpreted as the centre p being a well-defined point at infinity with either infinite or zero radius squared (the latter for the case of a null hyperplane). Knowing p (and r2) in this case does not determine the hyperplane's position, though, only its the orientation in space.
The radius squared may take on a positive, zero or negative value. When the quadratic form is definite, even though p and r2 may be determined from the above expressions, the set of vectors x satisfying the defining equation may be empty, as is the case in a Euclidean space for a negative radius squared.
Diameter and radius
Any pair of points, which need not be distinct, (including the option of up to one of these being a point at infinity) defines a diameter of a quasi-sphere. The quasi-sphere is the set of points for which the two displacement vectors from these two points are orthogonal.
Any point may be selected as a centre (including a point at infinity), and any other point on the quasi-sphere (other than a point at infinity) define a radius of a quasi-sphere, and thus specifies the quasi-sphere.
Partitioning
Referring to the quadratic form applied to the displacement vector of a point on the quasi-sphere from the centre (i.e. Q(x − p)) as the radius squared, in any pseudo-Euclidean space the quasi-spheres may be separated into three disjoint sets: those with positive radius squared, those with negative radius squared, those with zero radius squared.[lower-alpha 4]
In spaces with a positive-definite quadratic form (i.e. Euclidean space), the quasi-spheres with negative radius squared are the empty set, those with zero radius each consist of a single point, those with positive radius squared are standard n-spheres, and those with zero curvature are hyperplanes.
Notes
- ↑ Some authors exclude the definite cases, but in the context of this article, the qualifier indefinite will be used where this exclusion is intended.
- ↑ The associated symmetric bilinear form of a (real) quadratic form Q is defined such that Q(x) = B(x, x), and may may be determined as B(x, y) = 1/4(Q(x + y) − Q(x − y)). See Polarization identity for variations of this identity.
- ↑ Though not mentioned in the source, we must exclude the combination b = 0 and a = 0.
- ↑ A hyperplane (a quasi-sphere with infinite radius or zero curvature) is partitioned with quasi-spheres to which it is tangent. The three sets may be defined according to whether the quadratic form applied to a vector that is a normal of the tangent hypersurface is positive, zero or negative. The three sets of objects are preserved under conformal transformations of the space.
References
- ↑ Jayme Vaz, Jr.; Roldão da Rocha, Jr. (2016). An Introduction to Clifford Algebras and Spinors. Oxford University Press. p. 140. ISBN 9780191085789.
- ↑ Ian R. Porteous (1995), Clifford Algebras and the Classical Groups, Cambridge University Press
| Dimensional spaces |  | |
|---|---|---|
| Other dimensions | ||
| Polytopes and shapes | ||
| Dimensions by number | ||
Category | ||